Technical Inventory
System
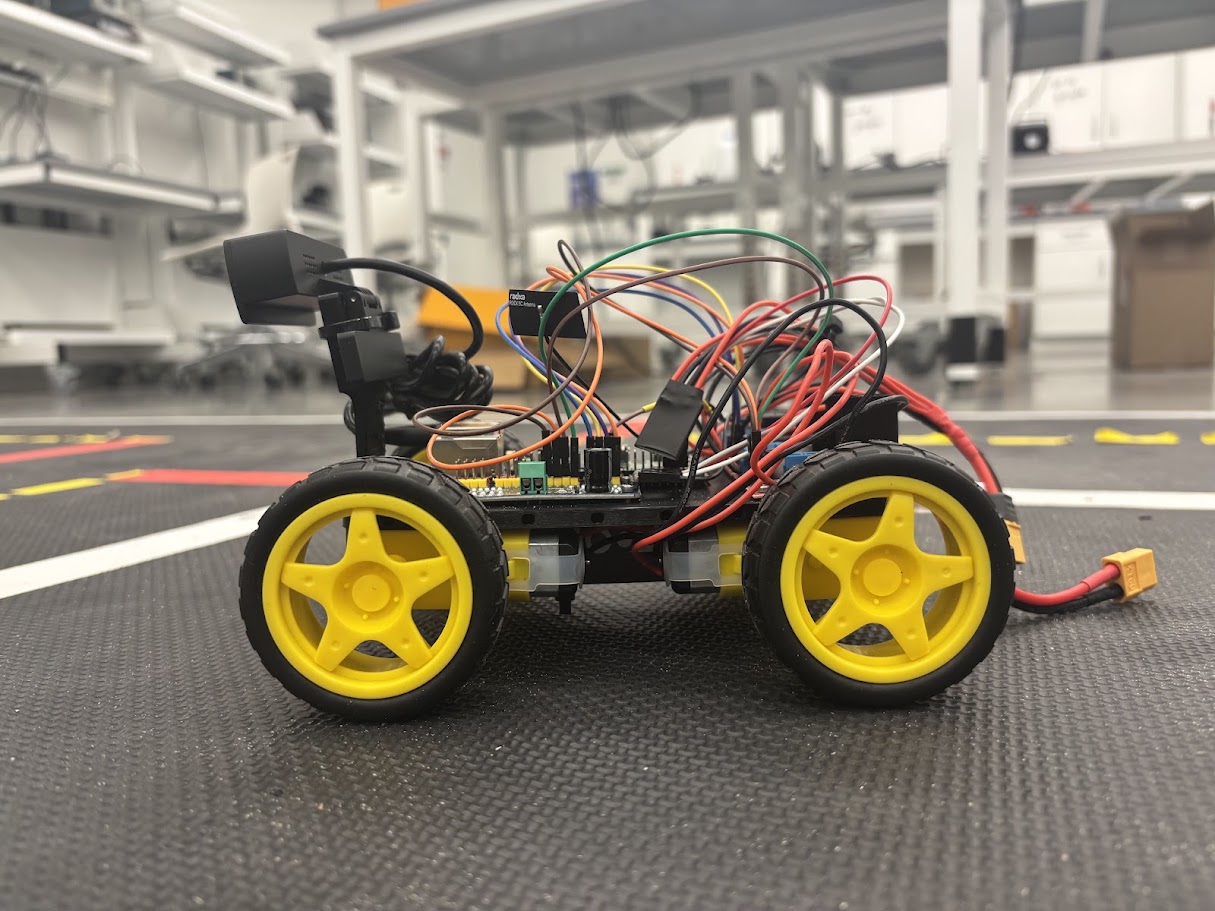
Autonomous Rover Platform
Engineered and assembled the low cost, open source GooseBot robotics platform. This project combined 3D printing and custom hardware in addition to custom object detection code that was deployed and tested to allow GooseBot to drive around a test track. Implemented and experimented with basic sign and rubber duck detection using test photos and machine learning allowing the GooseBot to detect up to 3 road signs, 3 road markings, and 2 objects.
Tools Used:
ubuntu
VIM
SSH
vscode
Roboflow
Python
Architecture
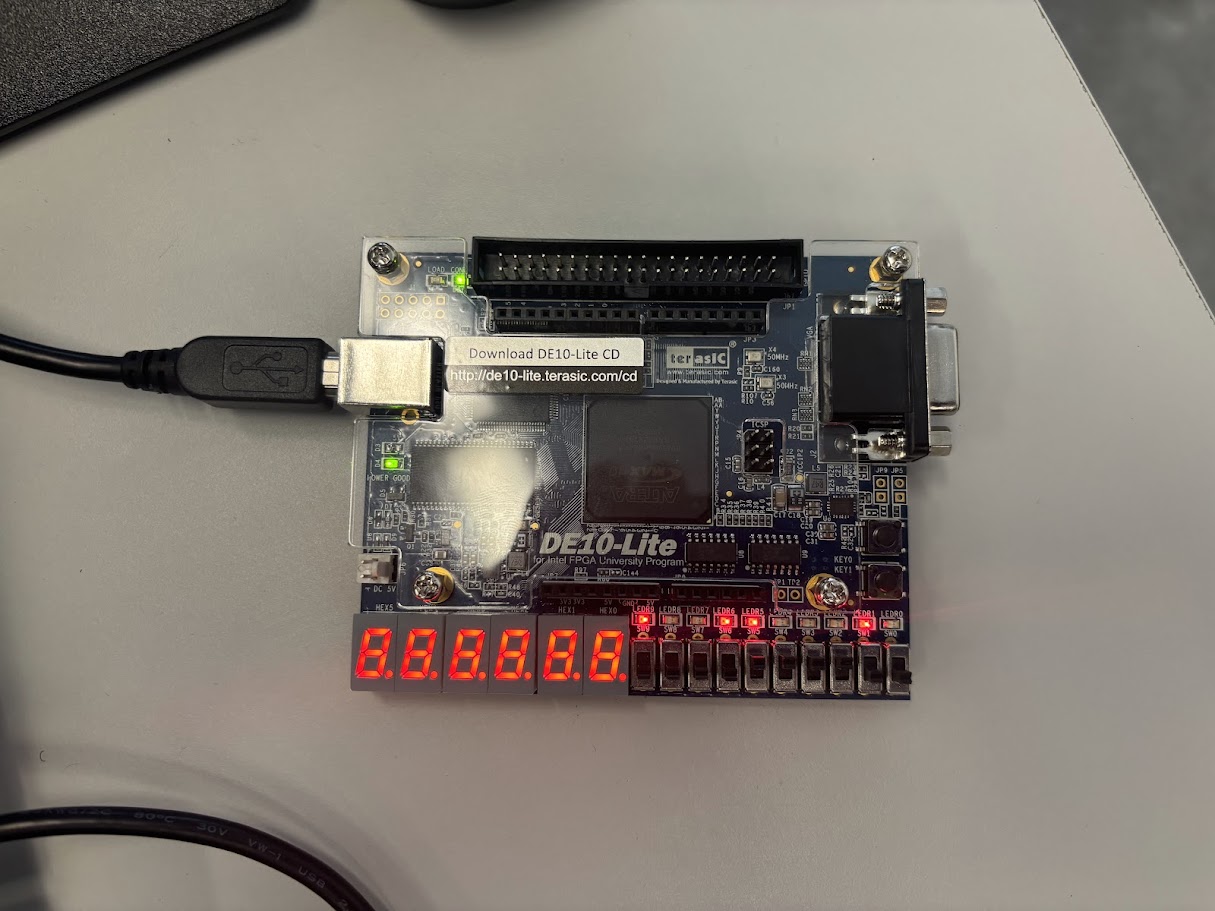
32-Bit MIPS Processor
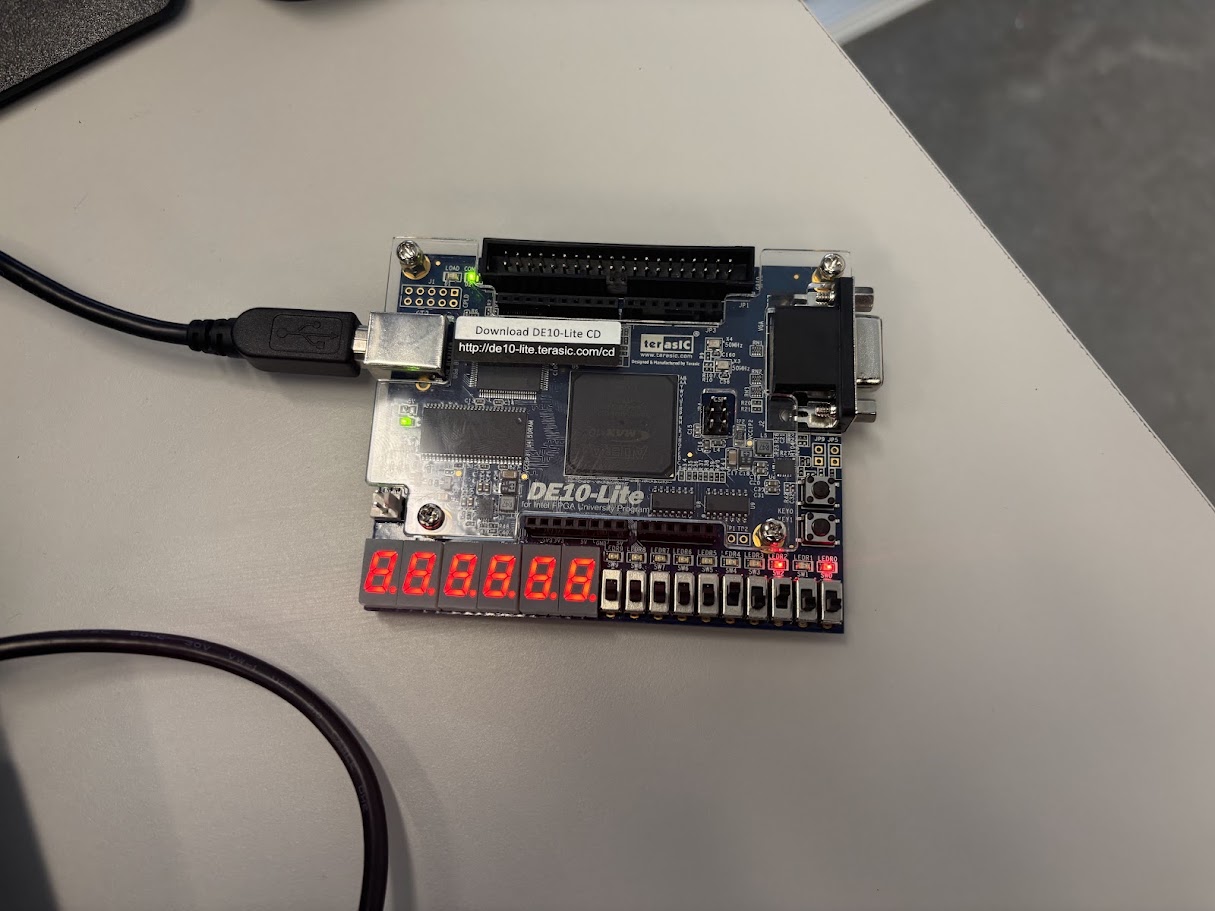
Designed and built a full-32 bit CPU that supports 10+ instructions as well as the ability to input data and display outputs via the onboard switches and leds. Intel Quartus Prime and the DE10-Lite were utilized to upload firmware written with the RISC-V architecture. Custom ROMs were uploaded and tested to confirm instructions worked and to demonstrate.
Tools Used:
Intel Quartus Prime
DE10-Lite
Verilog
SystemVerilog
Hardware
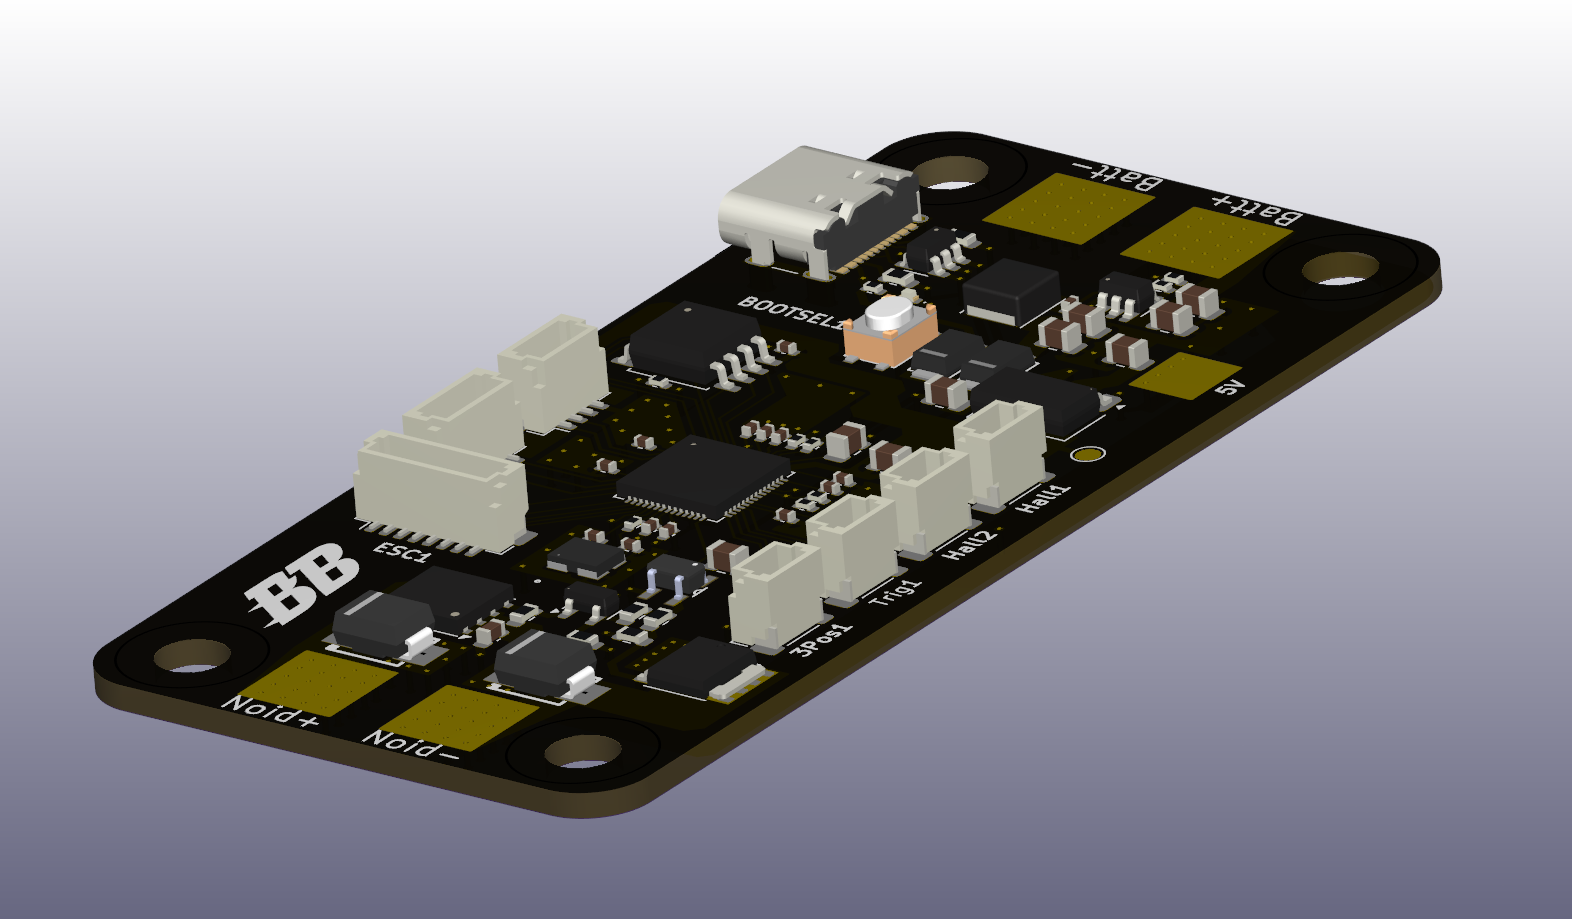
Solenoid Driver PCB
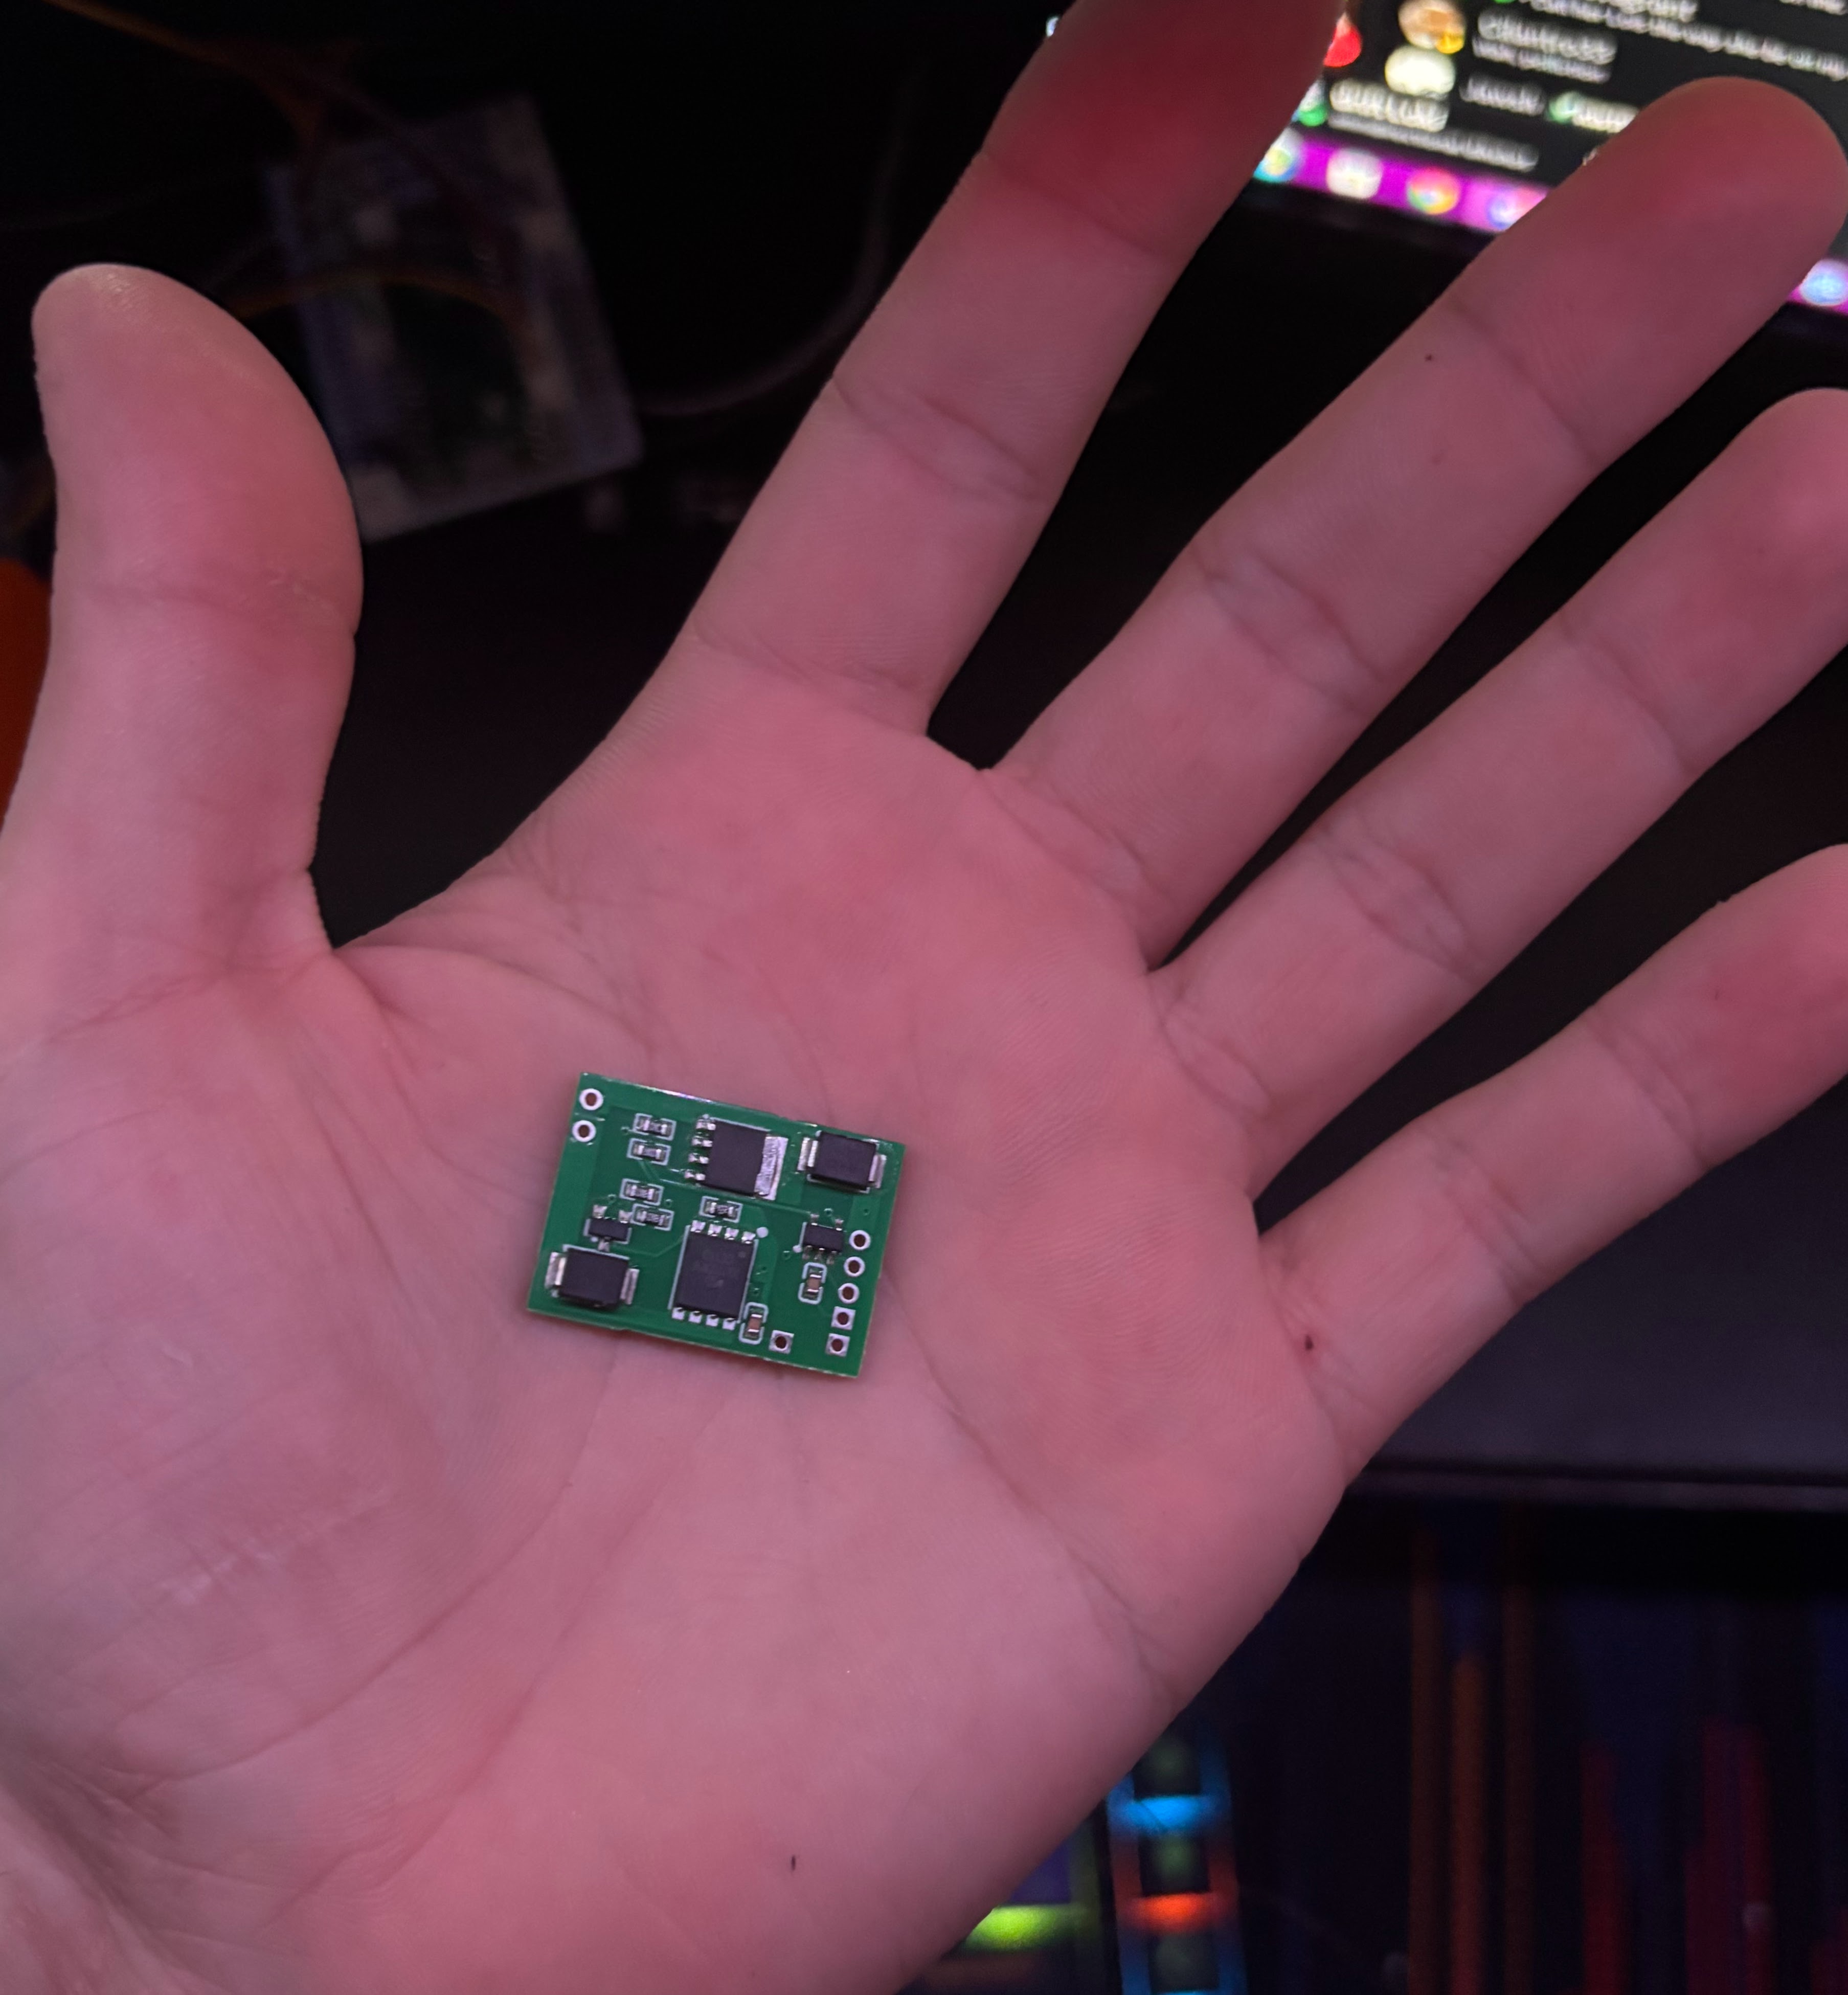
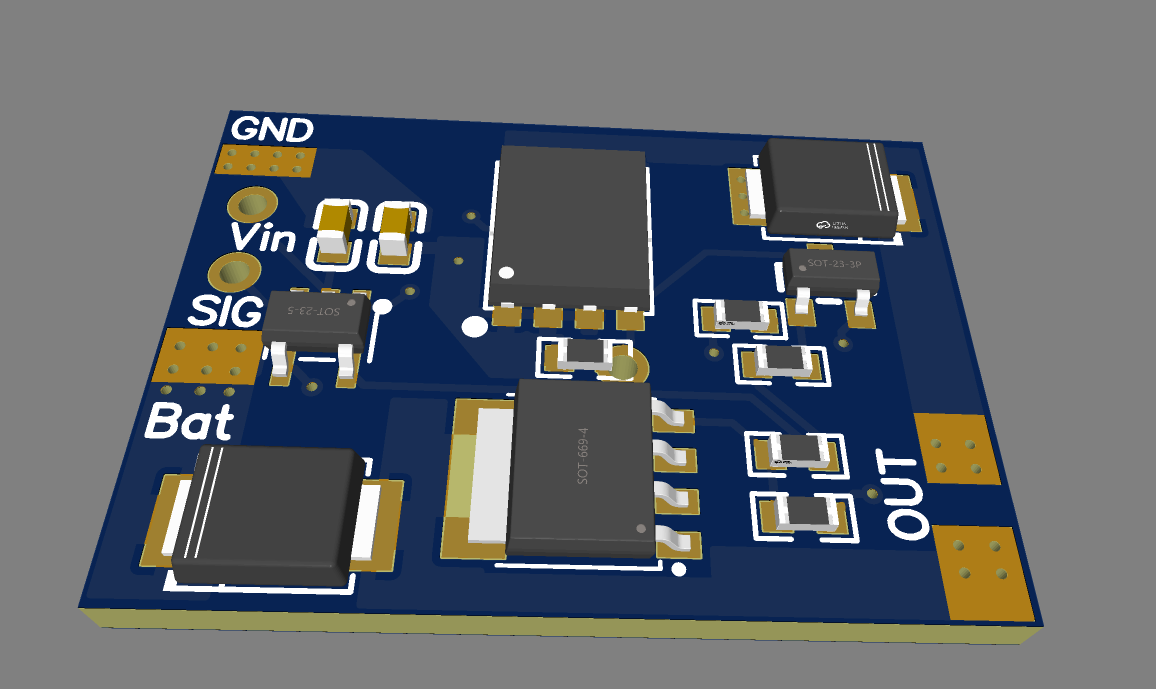
Designed and fabricated a circuit that handles powering and the fast field collapse of a solenoid. An array of P-type and N-type MOSFETs were used in conjunction with Zener Diodes to allow the magnet field to quickly propagate and collapse on the solenoid. A modified half H-bridge design allowed the circuit to properly power the solenoid and drain excess current to the battery reducing heat creating a ‘regenerative braking property’, which produced 25 full actuations per second. A custom PCB was produced using EasyEDA and KiCad to bring the design to life.
Tools Used:
LTSpice
KiCad
LCSC
JLCPCB
System
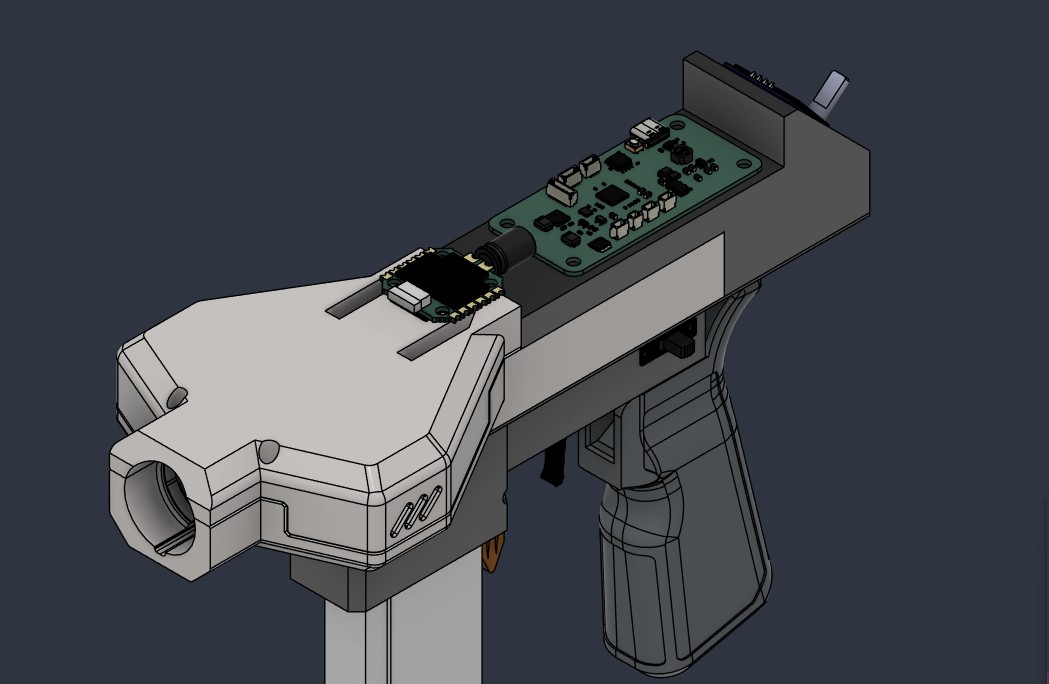
Brushless Nerf Blaster Design
Designed and fabricated custom PCBs integrating an RP2040, MOSFET-driven solenoid control, and brushless motor control to produce a high power, competition ready blaster system. This design fires darts at 25 per second at a velocity of 220 feet per second. This project utilized CAD modeling and 3D printing to design and manufacture components to secure electronics and integrate the system fully.
Tools Used:
Arduino IDE
C/C++
KiCad
LCSC
JLCPCB
LTSpice
PlatformIO